Lingpeng Chen
I am a second-year Ph.D. student at the Chinese University of Hong Kong, Shenzhen (CUHK-Shenzhen).
I received my bachelor’s degree from CUHK-Shenzhen, supervised by Prof. Huihuan Qian. During my undergraduate study, I was also a visiting student at the Carnegie Mellon University Robotics Institute, supervised by Prof. Katia Sycara.
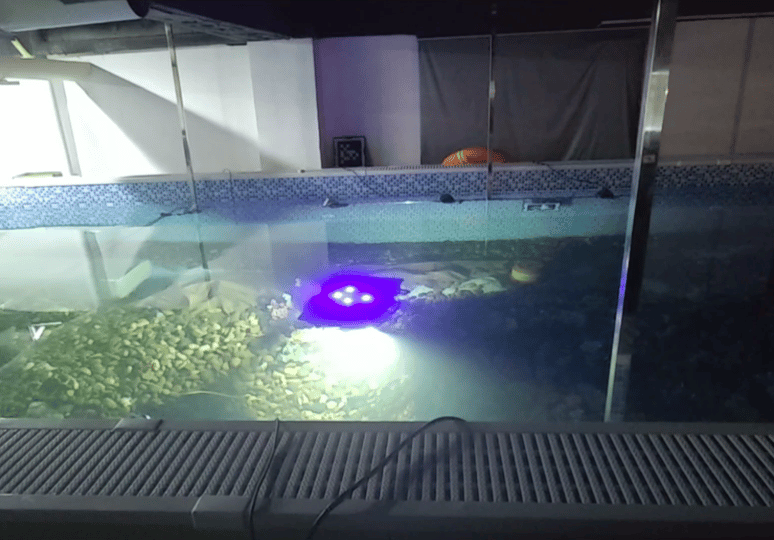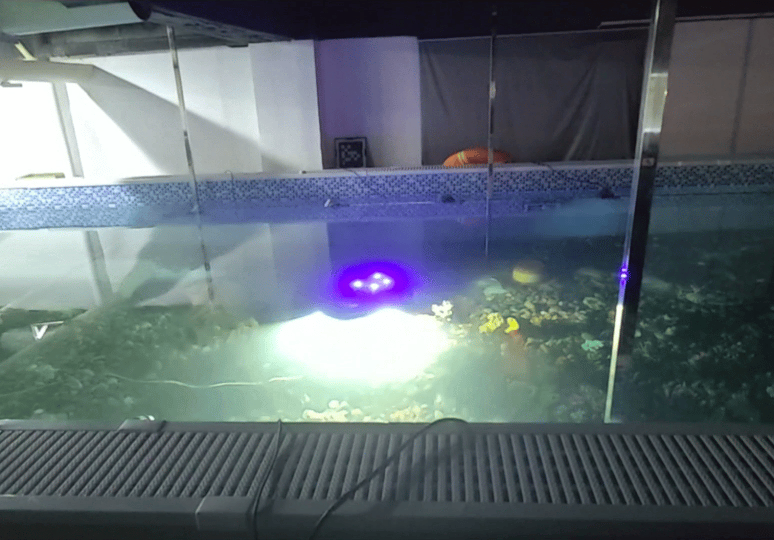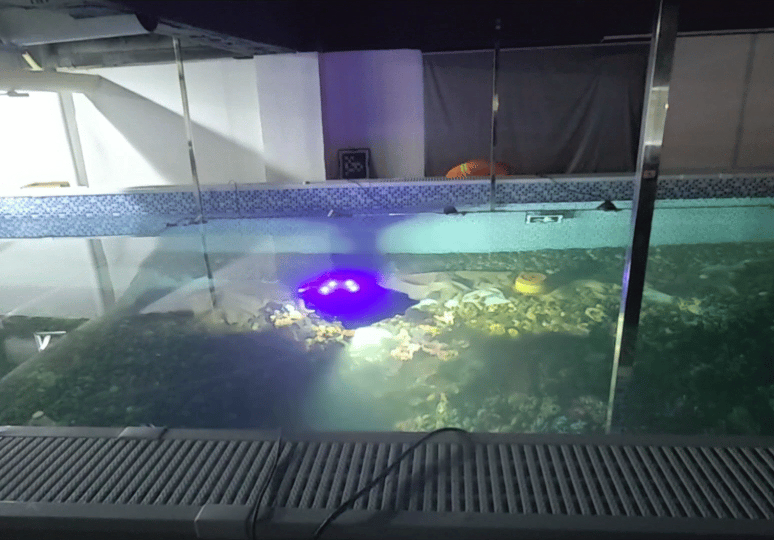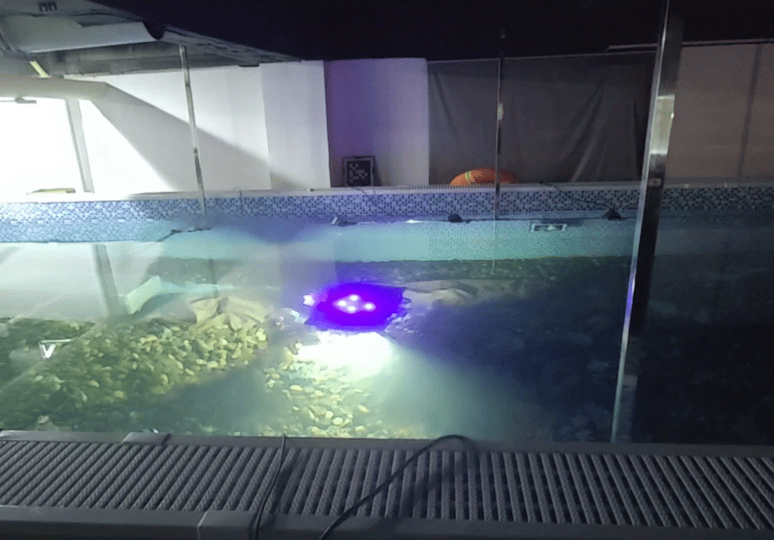
I am currently supervised by Prof. Junfeng Wu and Prof. Ziyang Hong, and we focus on underwater robotics. You are welcome to visit our lab website: LIAS @ CUHK-Shenzhen.
My research interests include:
- Robot perception and mapping in underwater visually degraded environments
- Robot informative path planning and control
- Underwater robotic systems
Recent News
- 2026-06: Our paper Provably Guaranteed Polytopic Uncertainty Quantification for SLAM is accepted by RSS 2026.
- 2026-06: Our paper Hierarchical Multi-Modal Planning for Fixed-Altitude Sparse Target Search and Sampling is accepted by IROS 2026.
- 2026-03: Our paper SonarSweep: Fusing Sonar and Vision for Robust 3D Reconstruction via Plane Sweeping is accepted by ICRA 2026.
- 2025-04: BESTAnP: Bi-Step Efficient and Statistically Optimal Estimator for Acoustic-n-Point Problem is accepted by IEEE RA-L (co-first author).
- 2025-01: Distributed Multi-robot Source Seeking in Unknown Environments with Unknown Number of Sources is selected as a Best Paper Finalist at ICRA 2025.